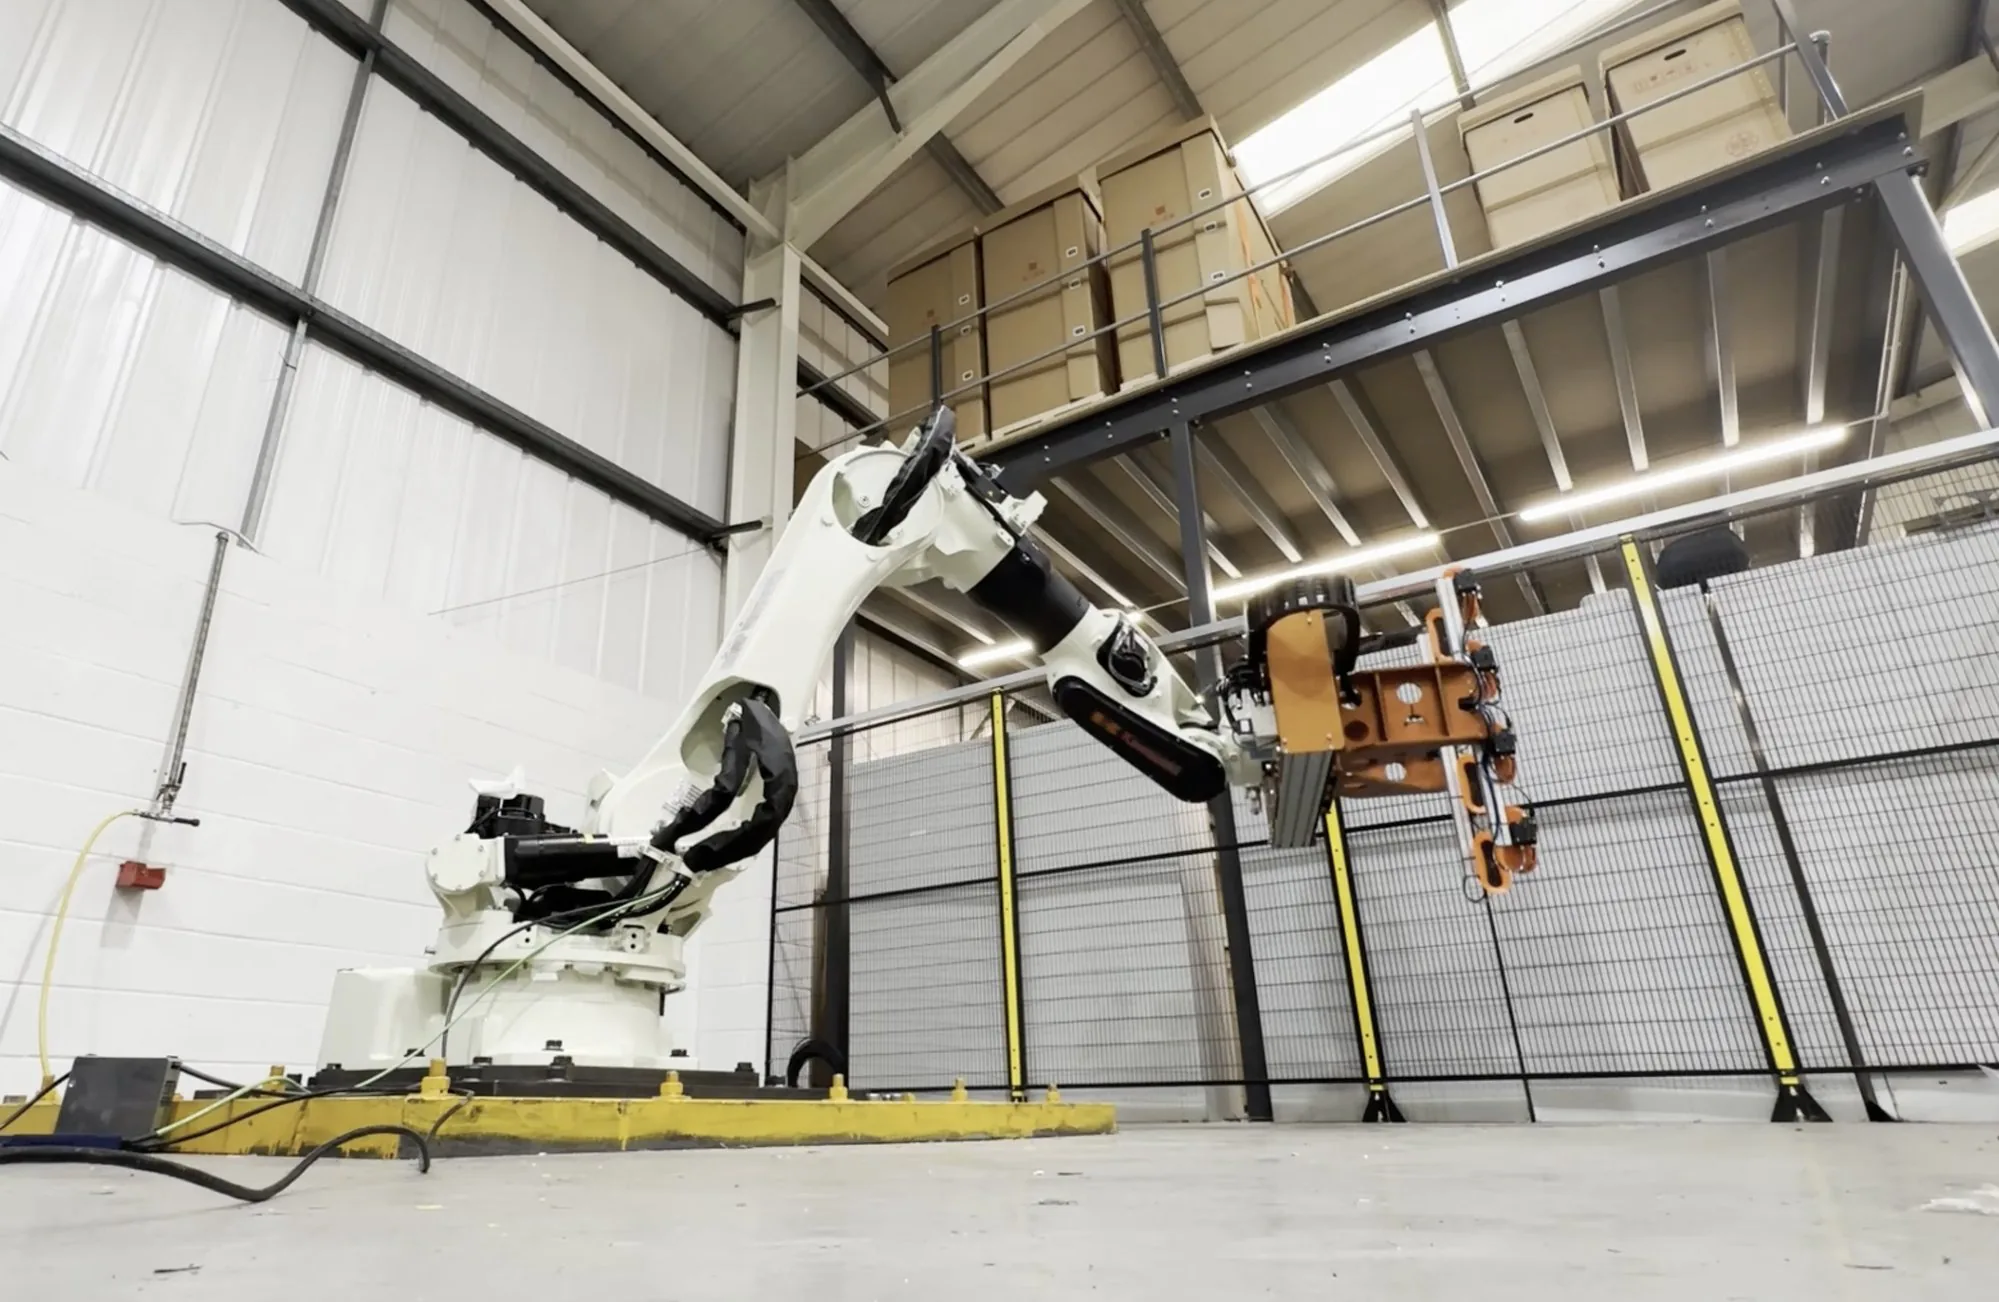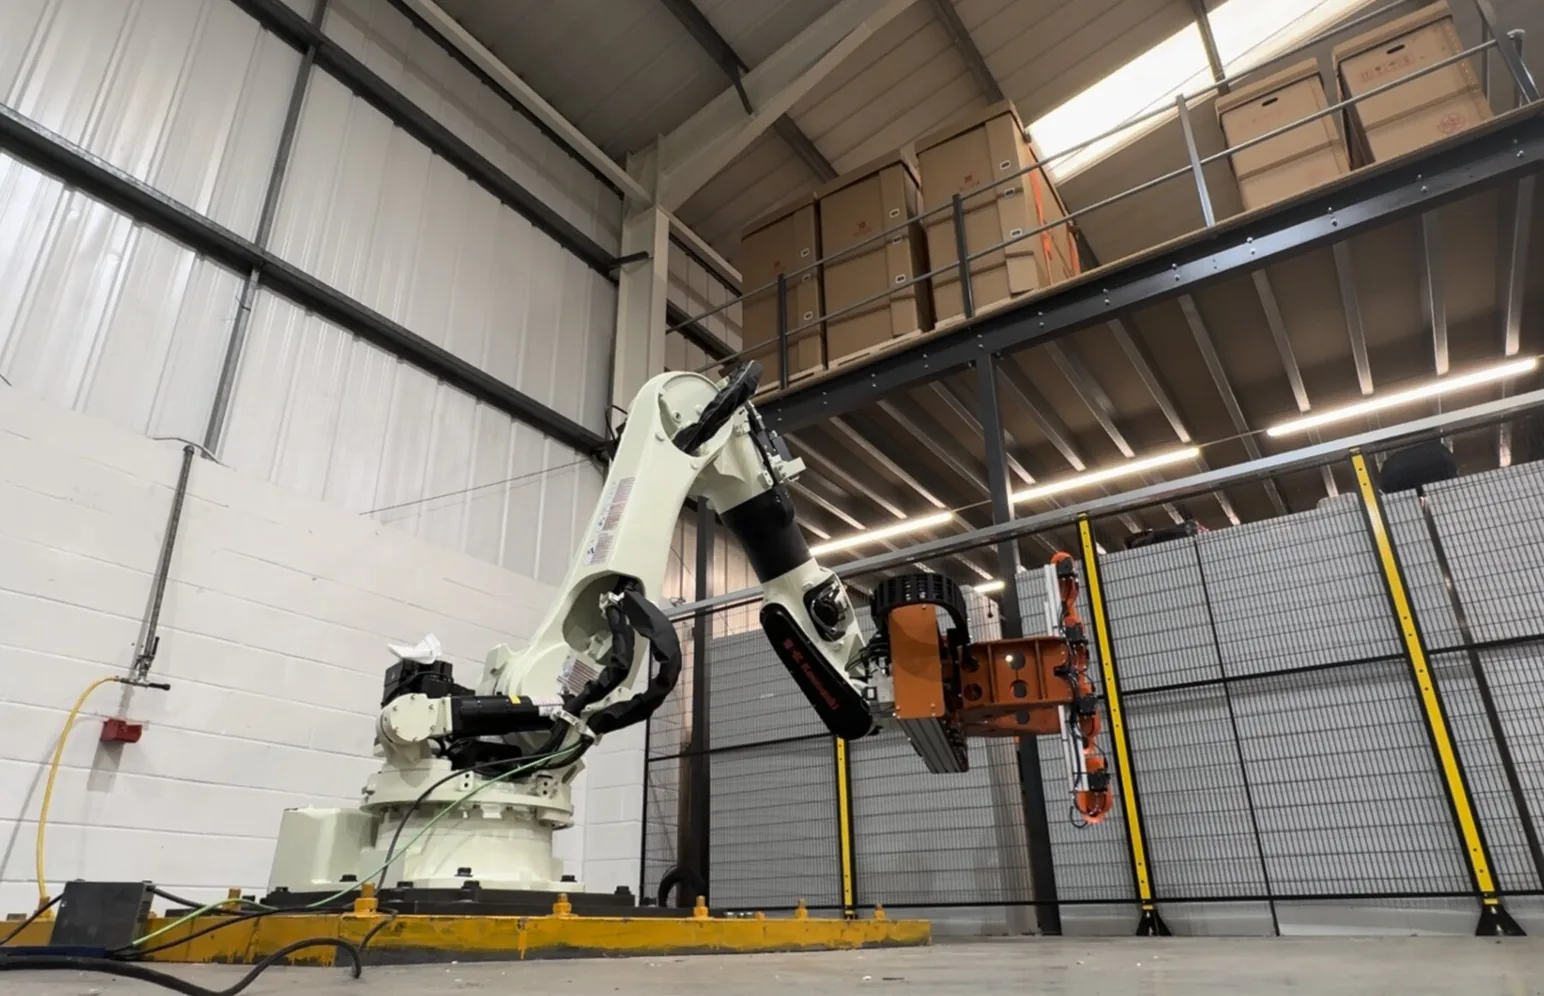
The Workhorse Of Industrial Automation
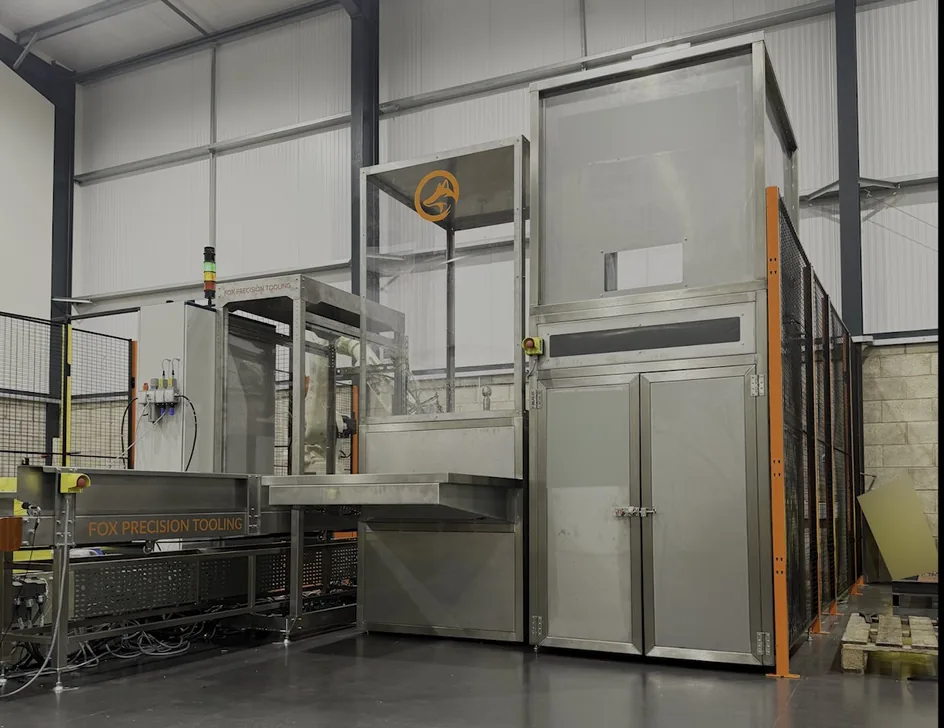
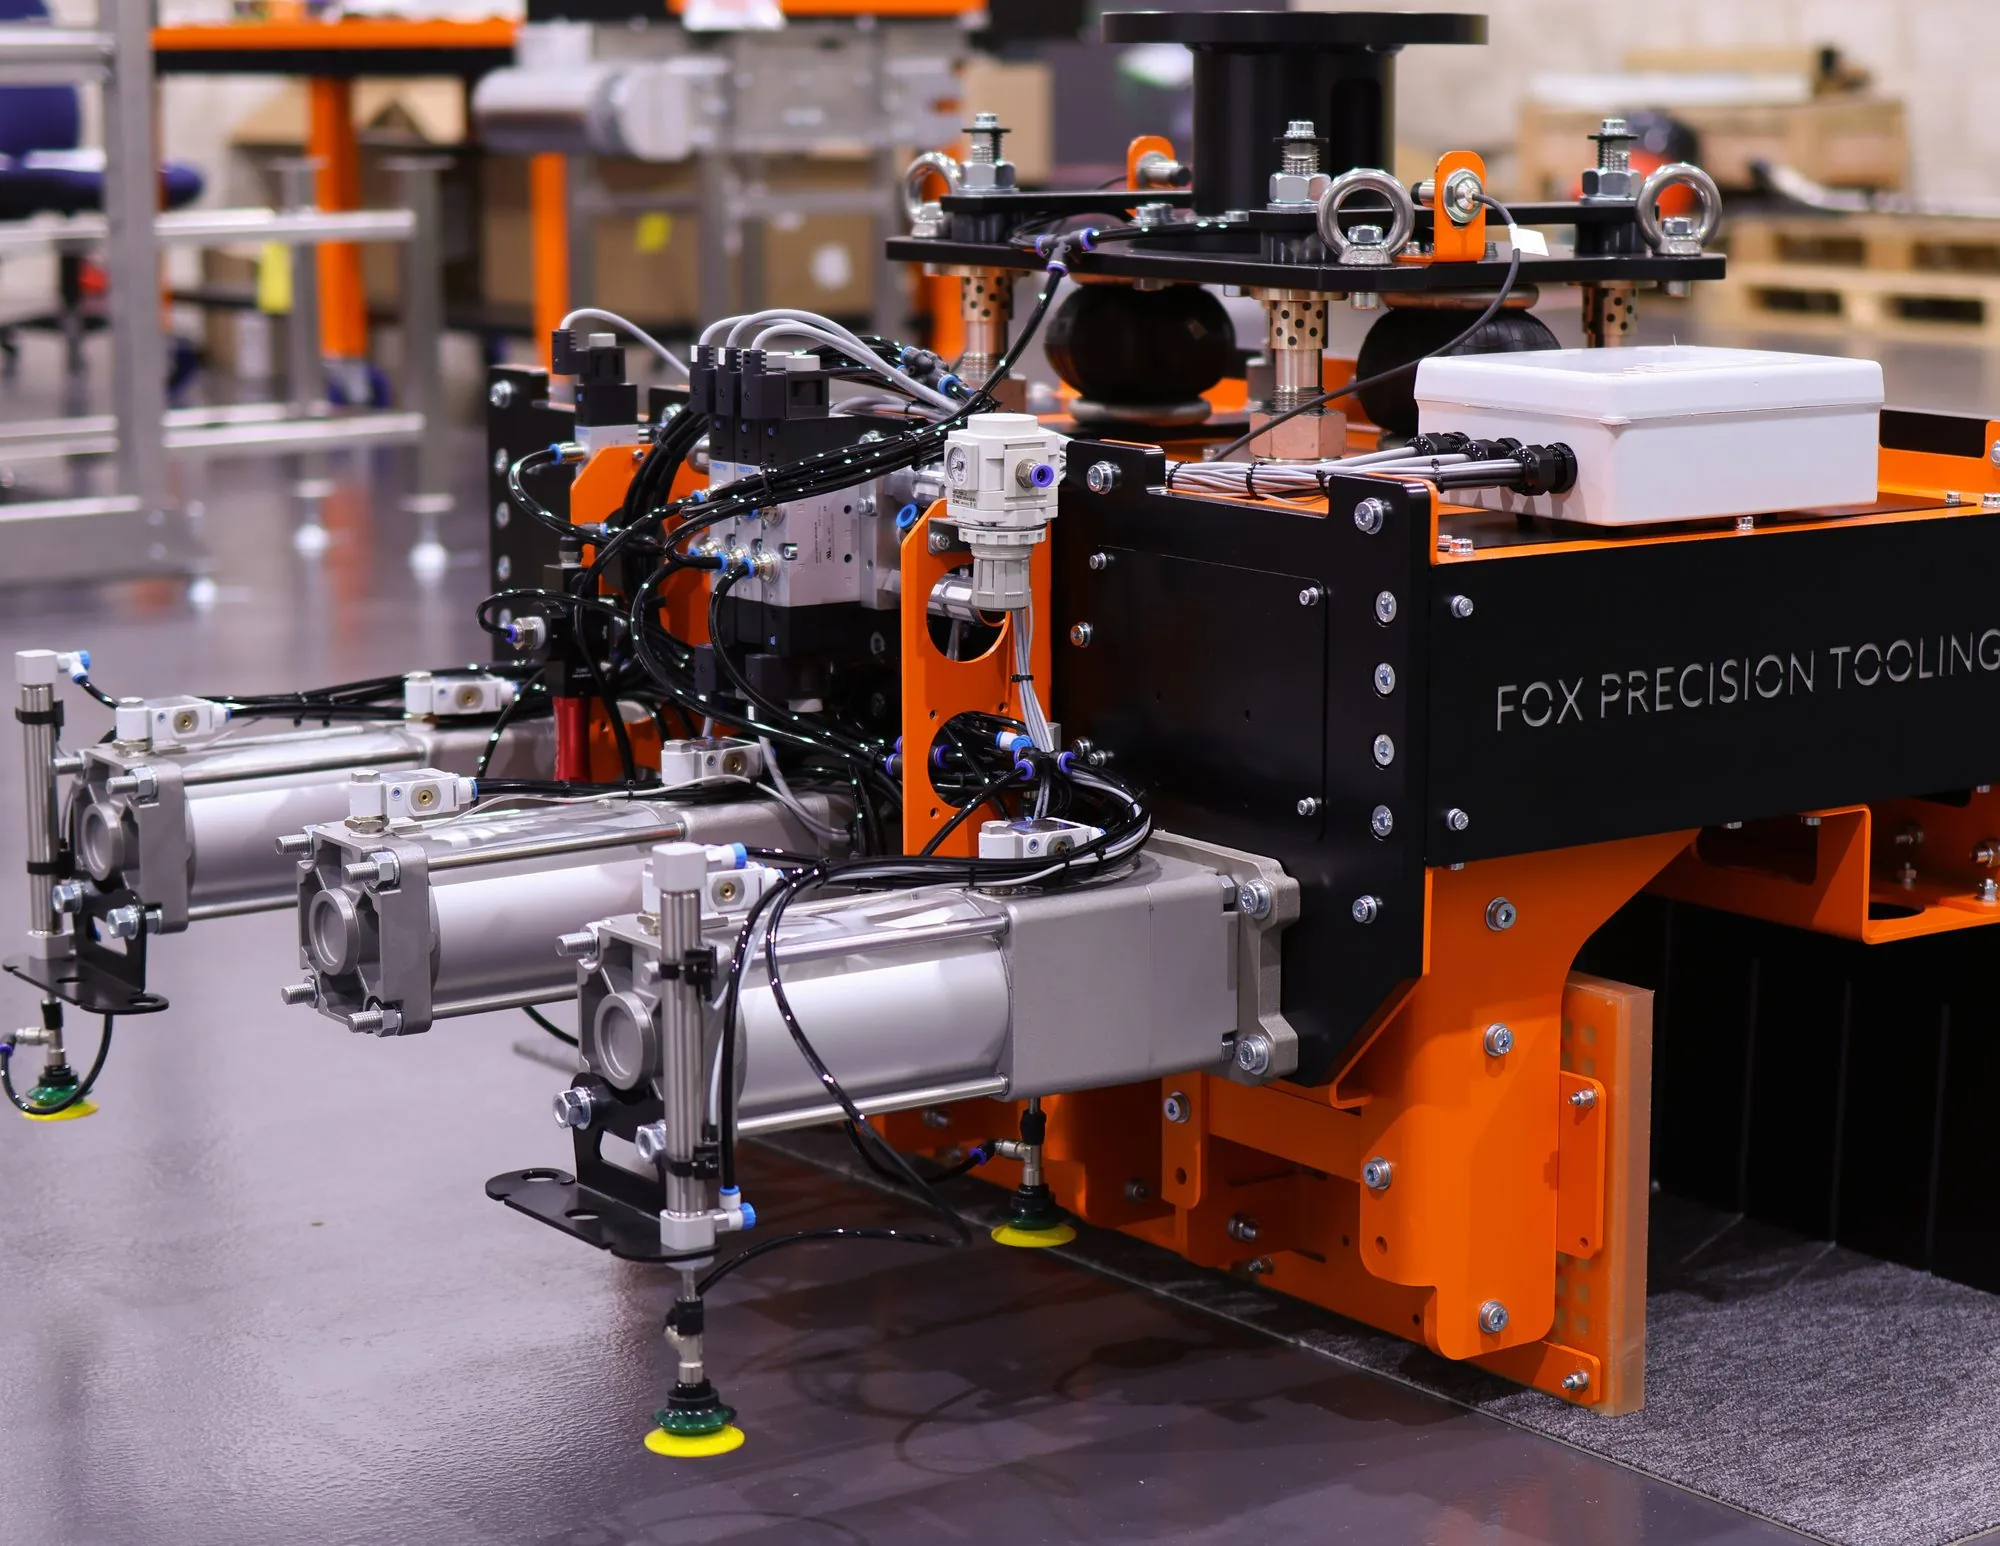
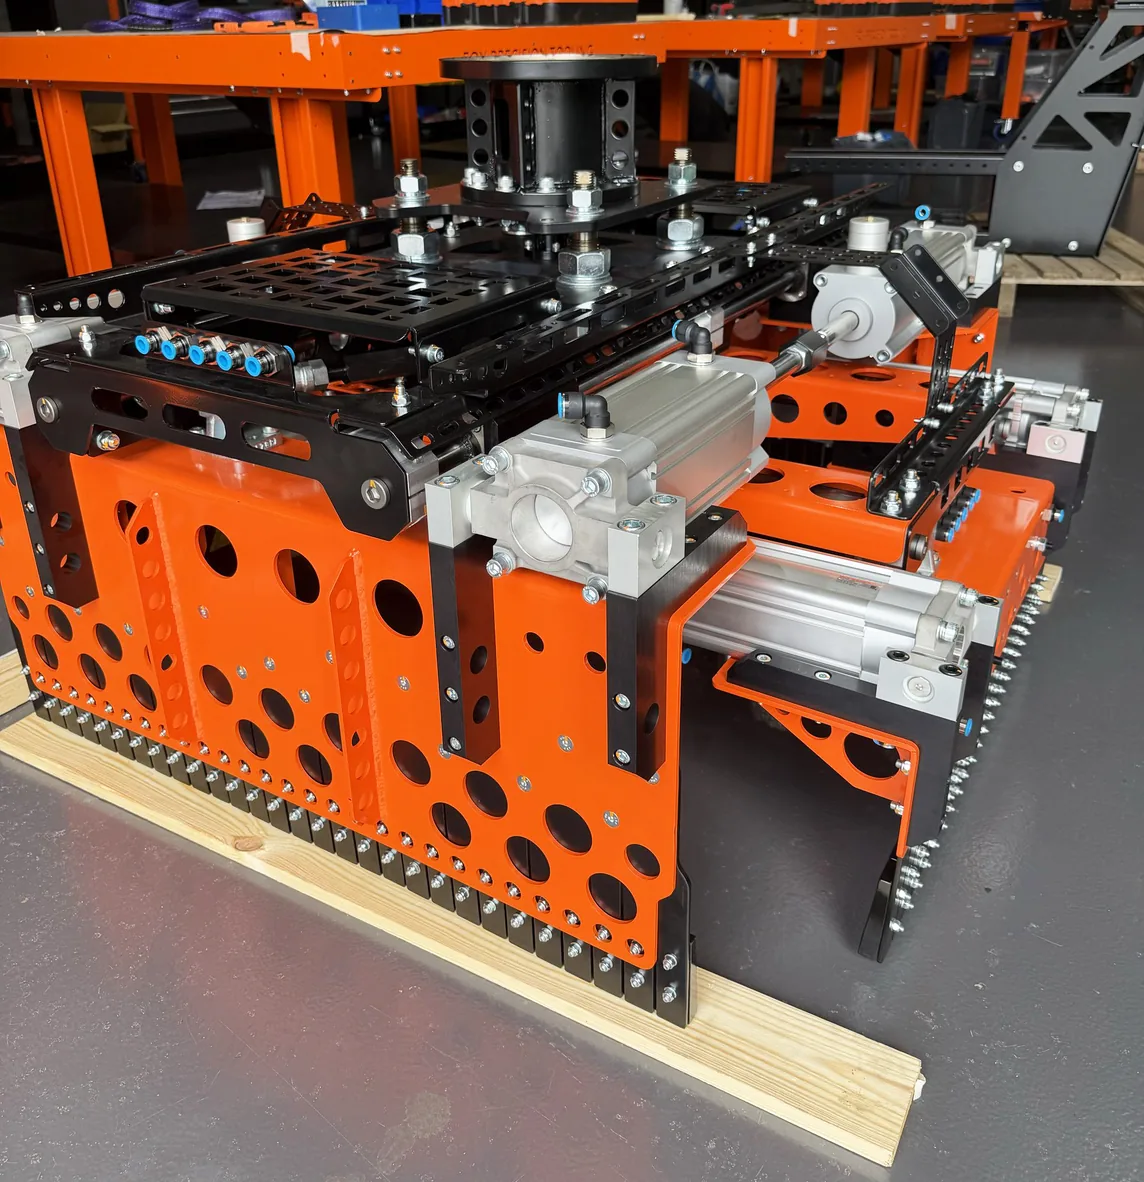
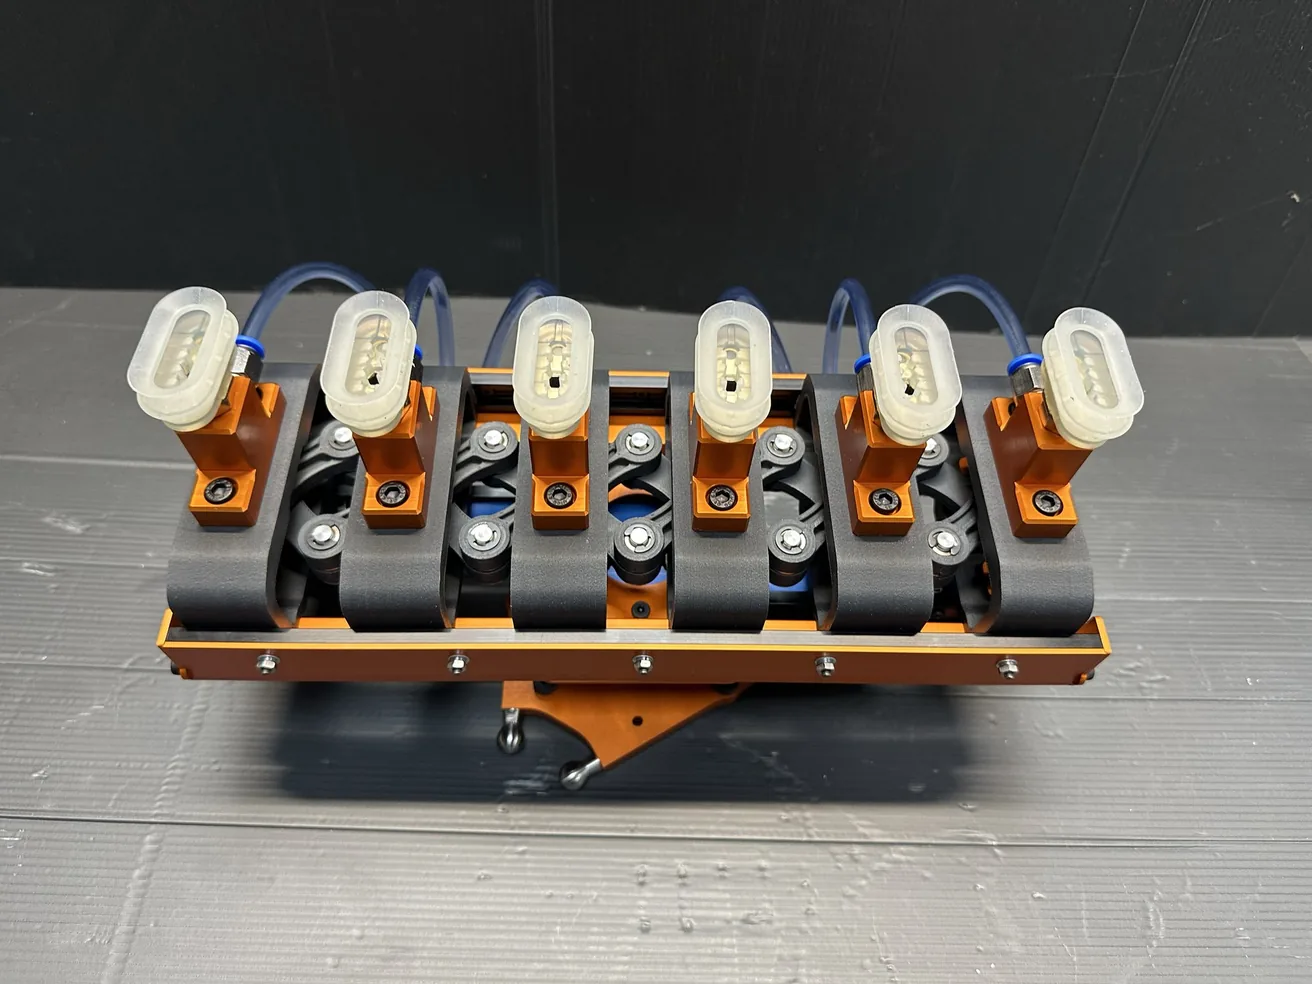
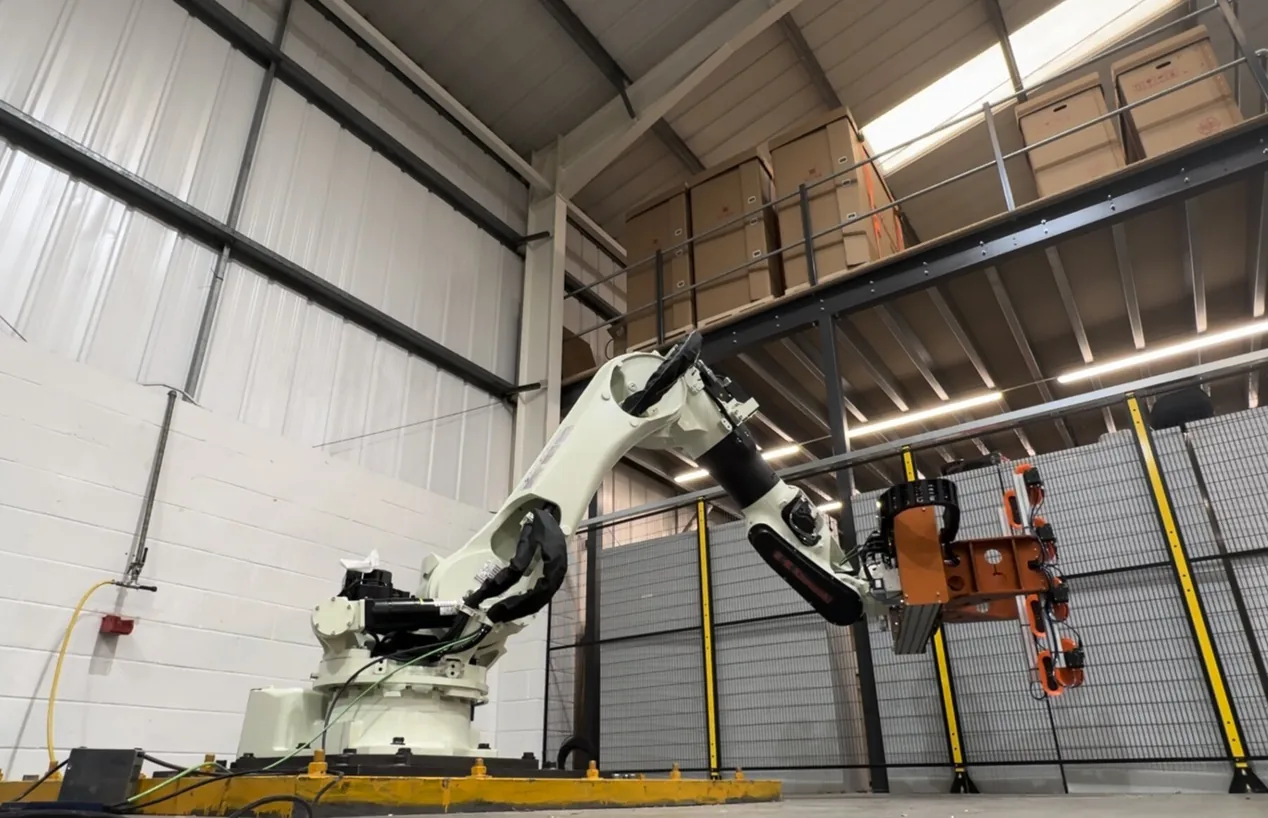
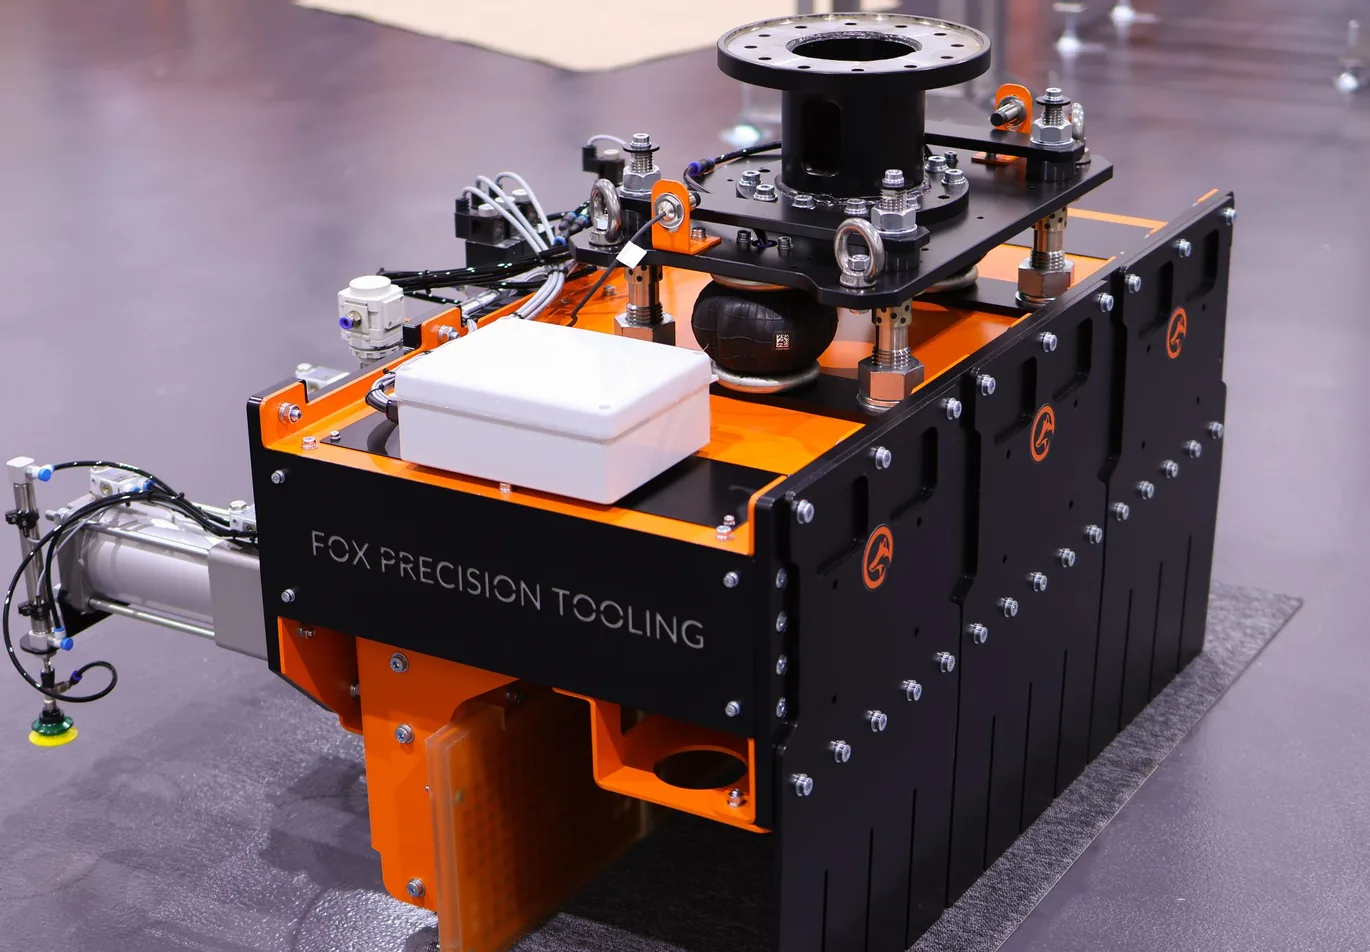
The workhorse of industrial automation. We design EOAT for 6-axis robots handling press transfer, palletising, welding and machine tending - matched to your exact wrist flange, payload and duty cycle.
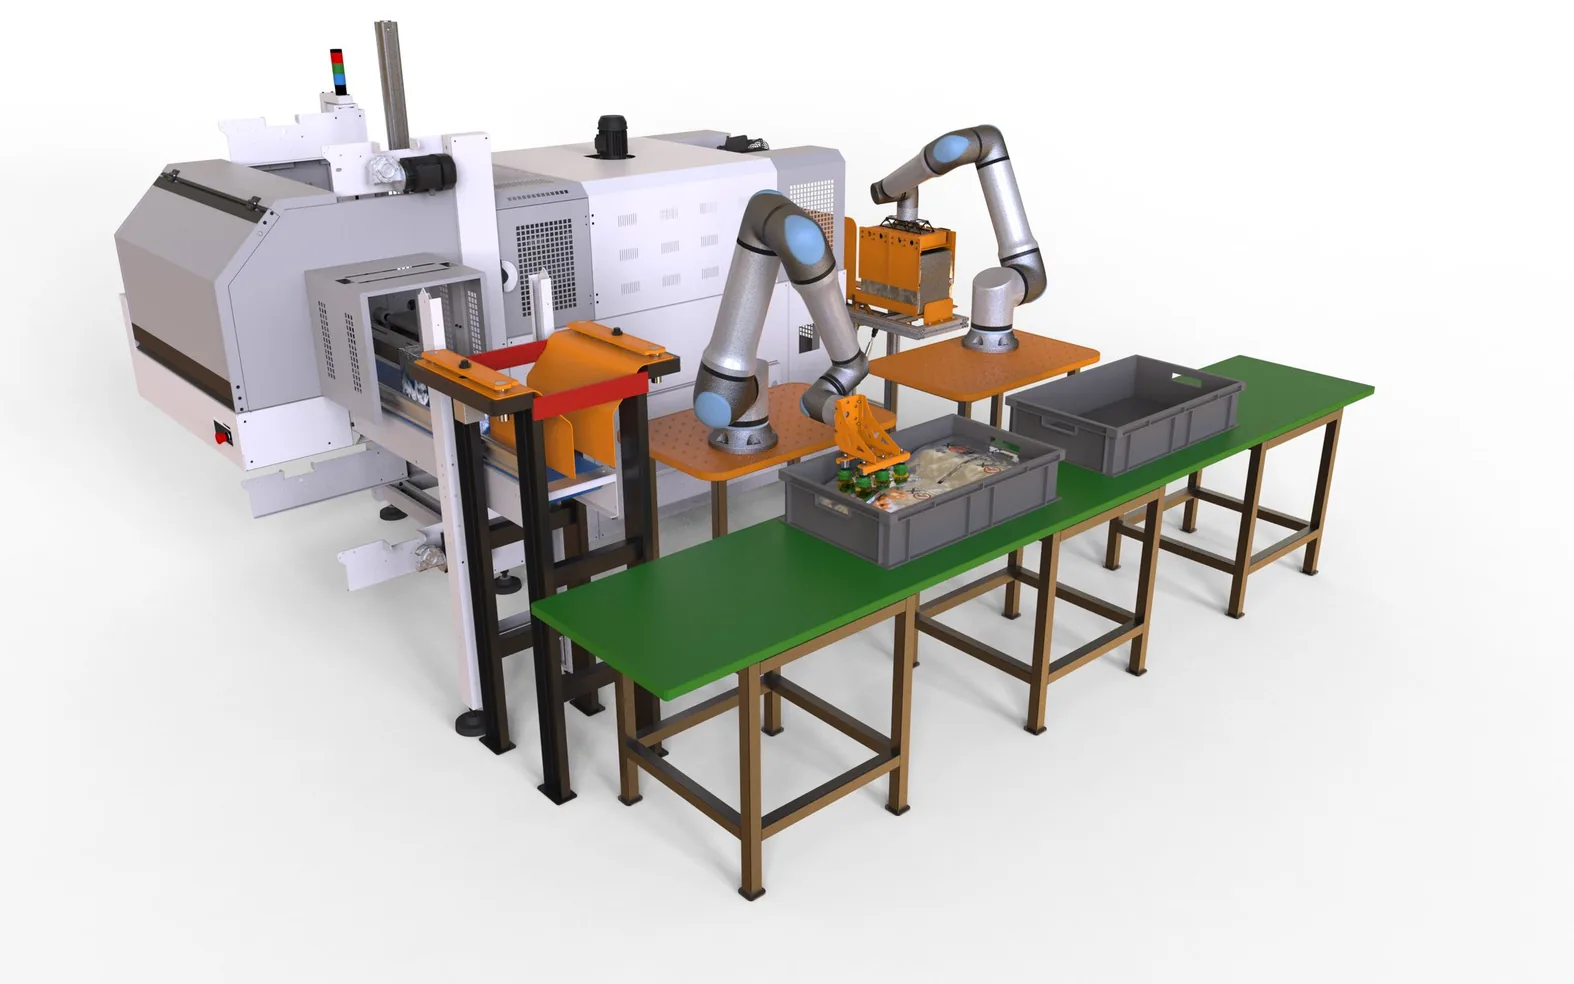
Designed To Work Safely Alongside People
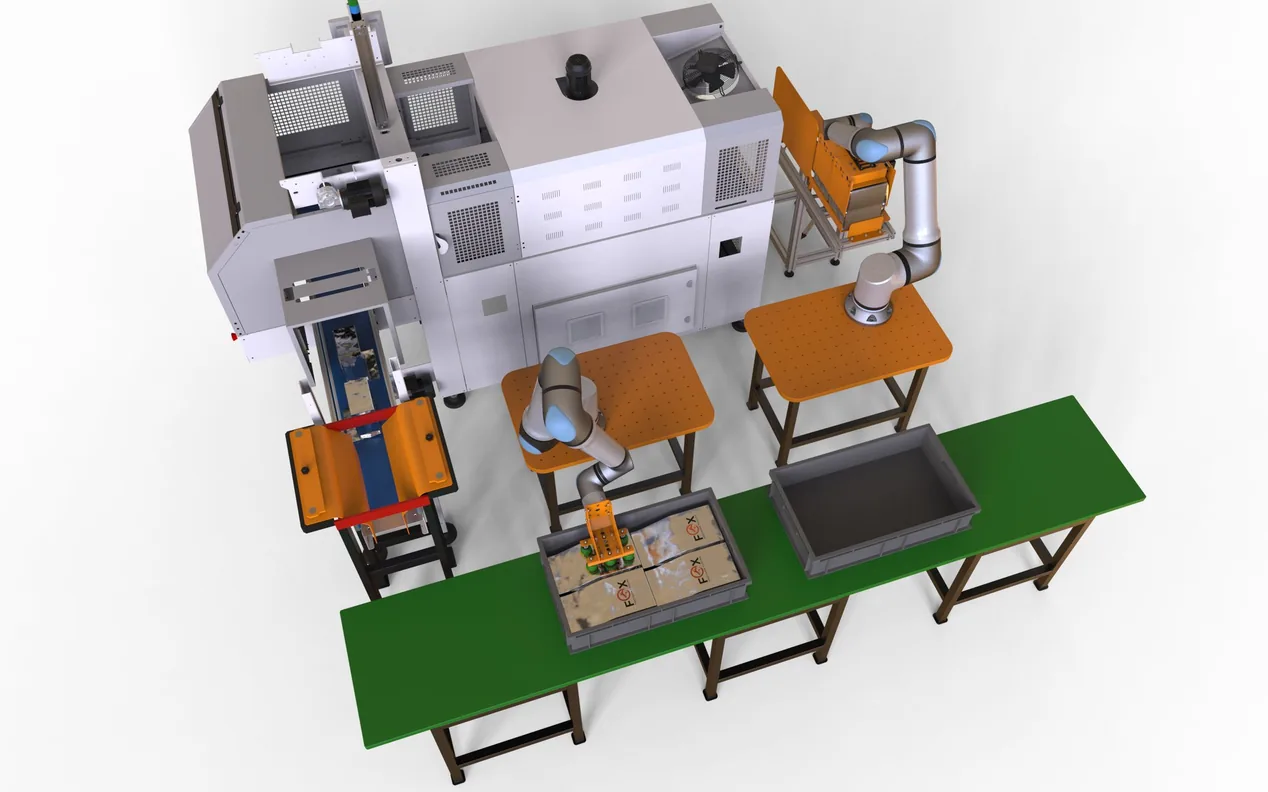
A collaborative robot works in the same space as your people, often with no fence or guarding. That changes what the EOAT is allowed to be - and it's a design brief we take seriously, so your cobot stays collaborative in practice, not just on paper.
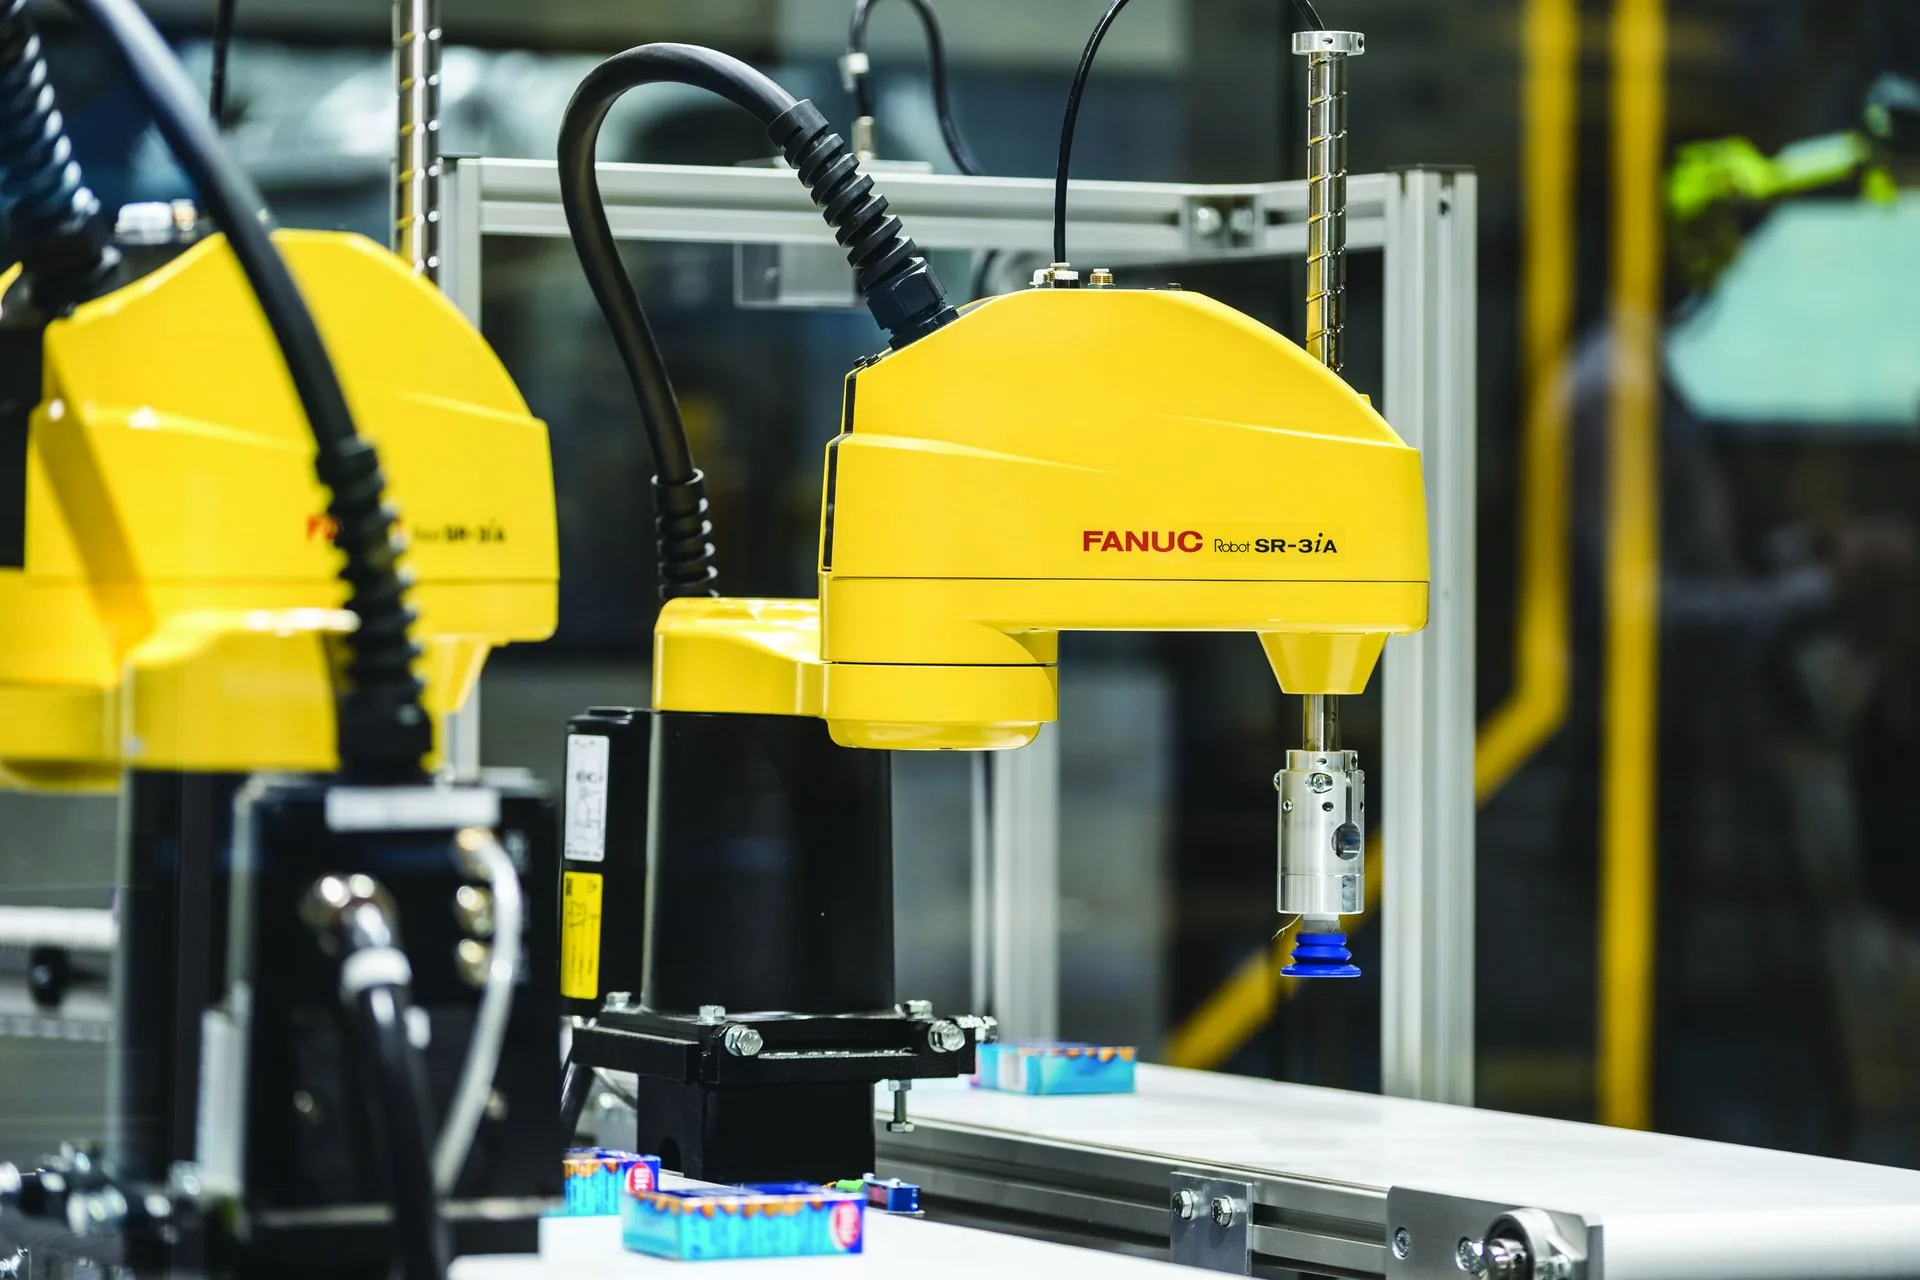
Speed And Precision For Flat-Plane Work
SCARA robots are built for flat-plane work. A rigid vertical axis and a fast, compliant horizontal reach give them speed and repeatability a six-axis robot can't match on the same task, in a compact footprint that fits into tighter cells.
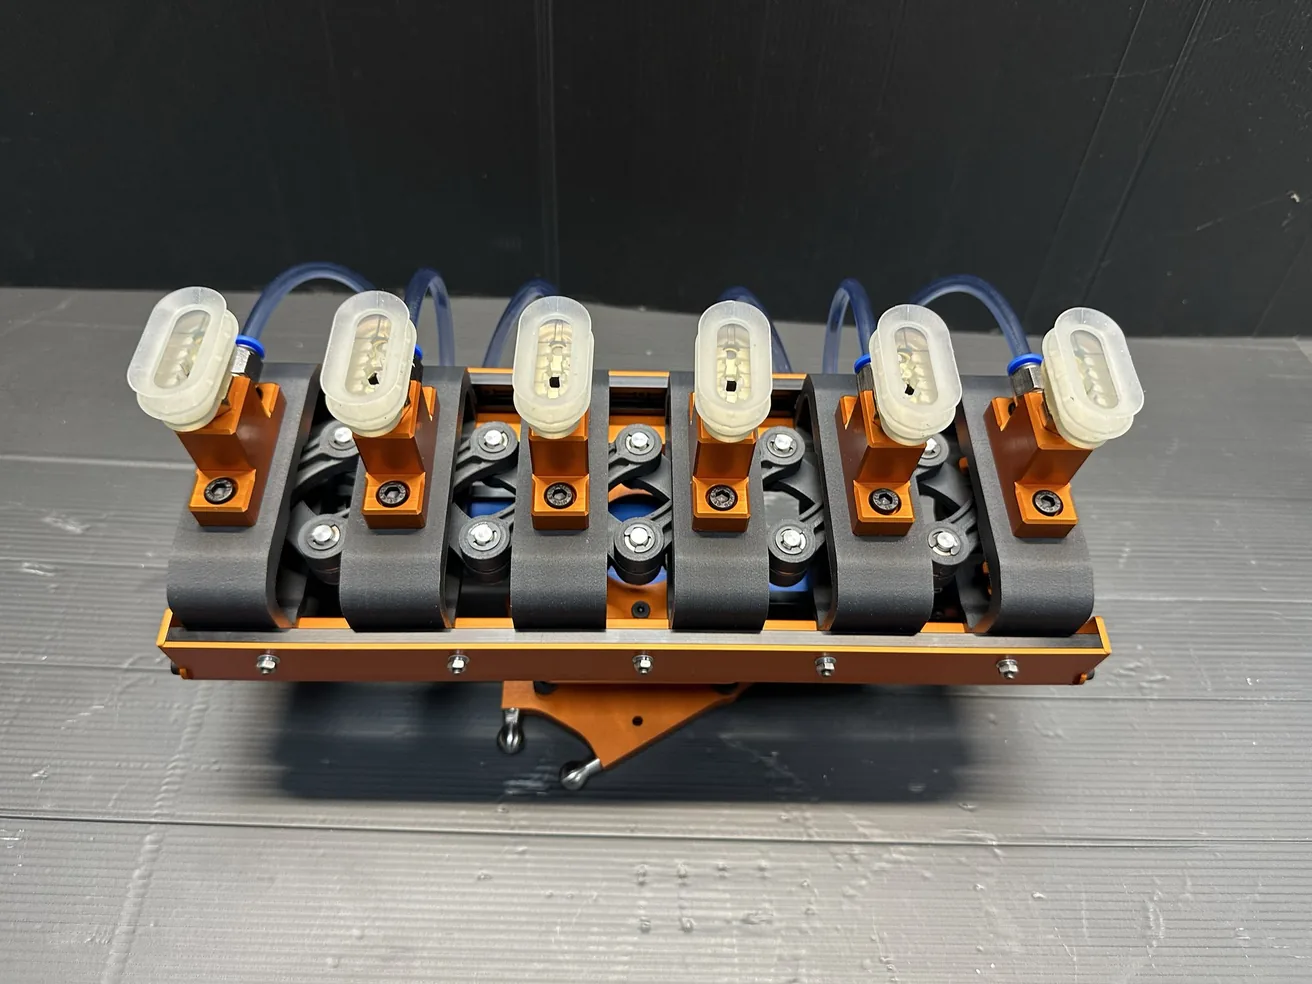
Built To Keep Up With High-Speed Picking
Delta robots are built for speed - three lightweight arms picking and placing faster than almost anything else on the floor. Our EOAT is engineered to keep up with it: light enough not to rob the robot of its pace, tough enough to survive the line it runs on.
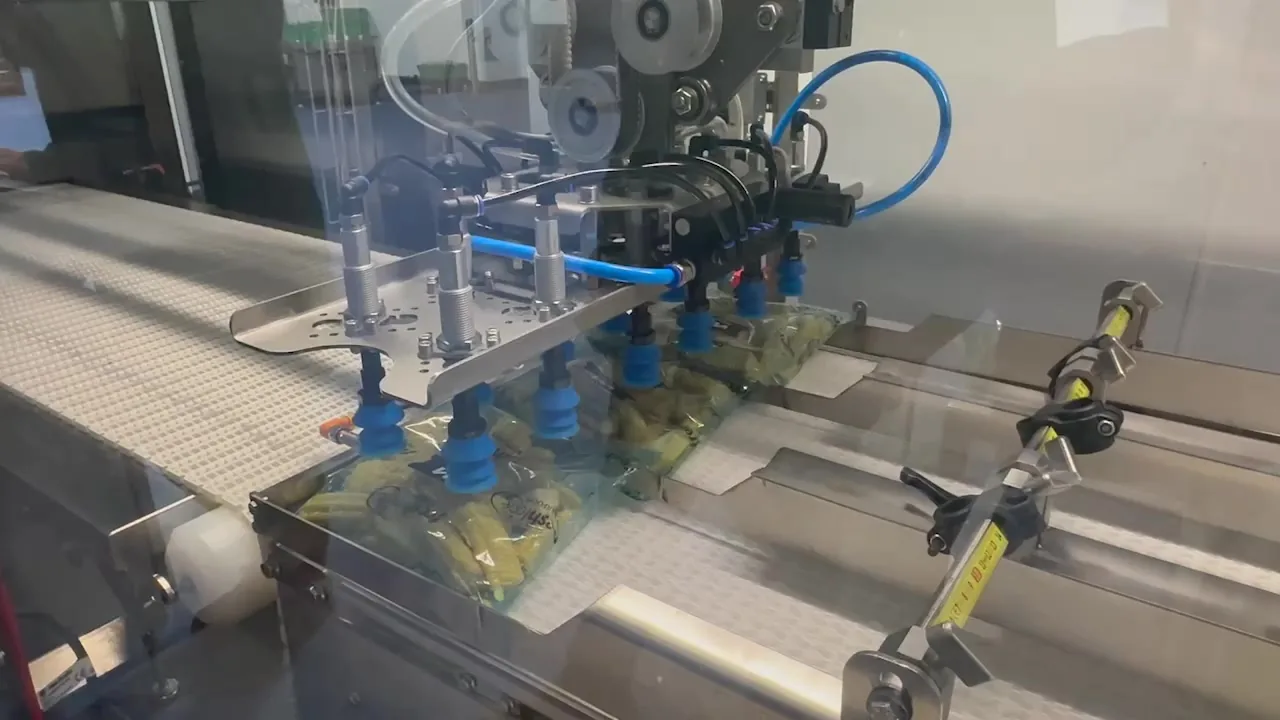
The Standard Choice For Injection Moulding Take-Out
Gantry and Cartesian robots move in straight lines. Traverse, kick, and vertical strokes take the EOAT into the mould, grip the part, and bring it straight back out - the standard choice for take-out on injection moulding machines.